

ROMA
Collection
Real-World Object-Centric Multi-Sensory Active Perception • 3 items • Updated • 1
Need help to make the dataset viewer work? Make sure to review how to configure the dataset viewer, and open a discussion for direct support.




Ruoxuan Feng*, Yutong Chen*, Ruihua Song, Huan Yang, Zhongyuan Wang, Guocai Yao, Di Hu✉
*Equal contribution ✉Corresponding author
This repository hosts the dataset of ROMA, an LLM-based system for Real-World Object-Centric Multi-Sensory Active Perception. The model checkpoint is released separately as GeWu-Lab/ROMA-7B.
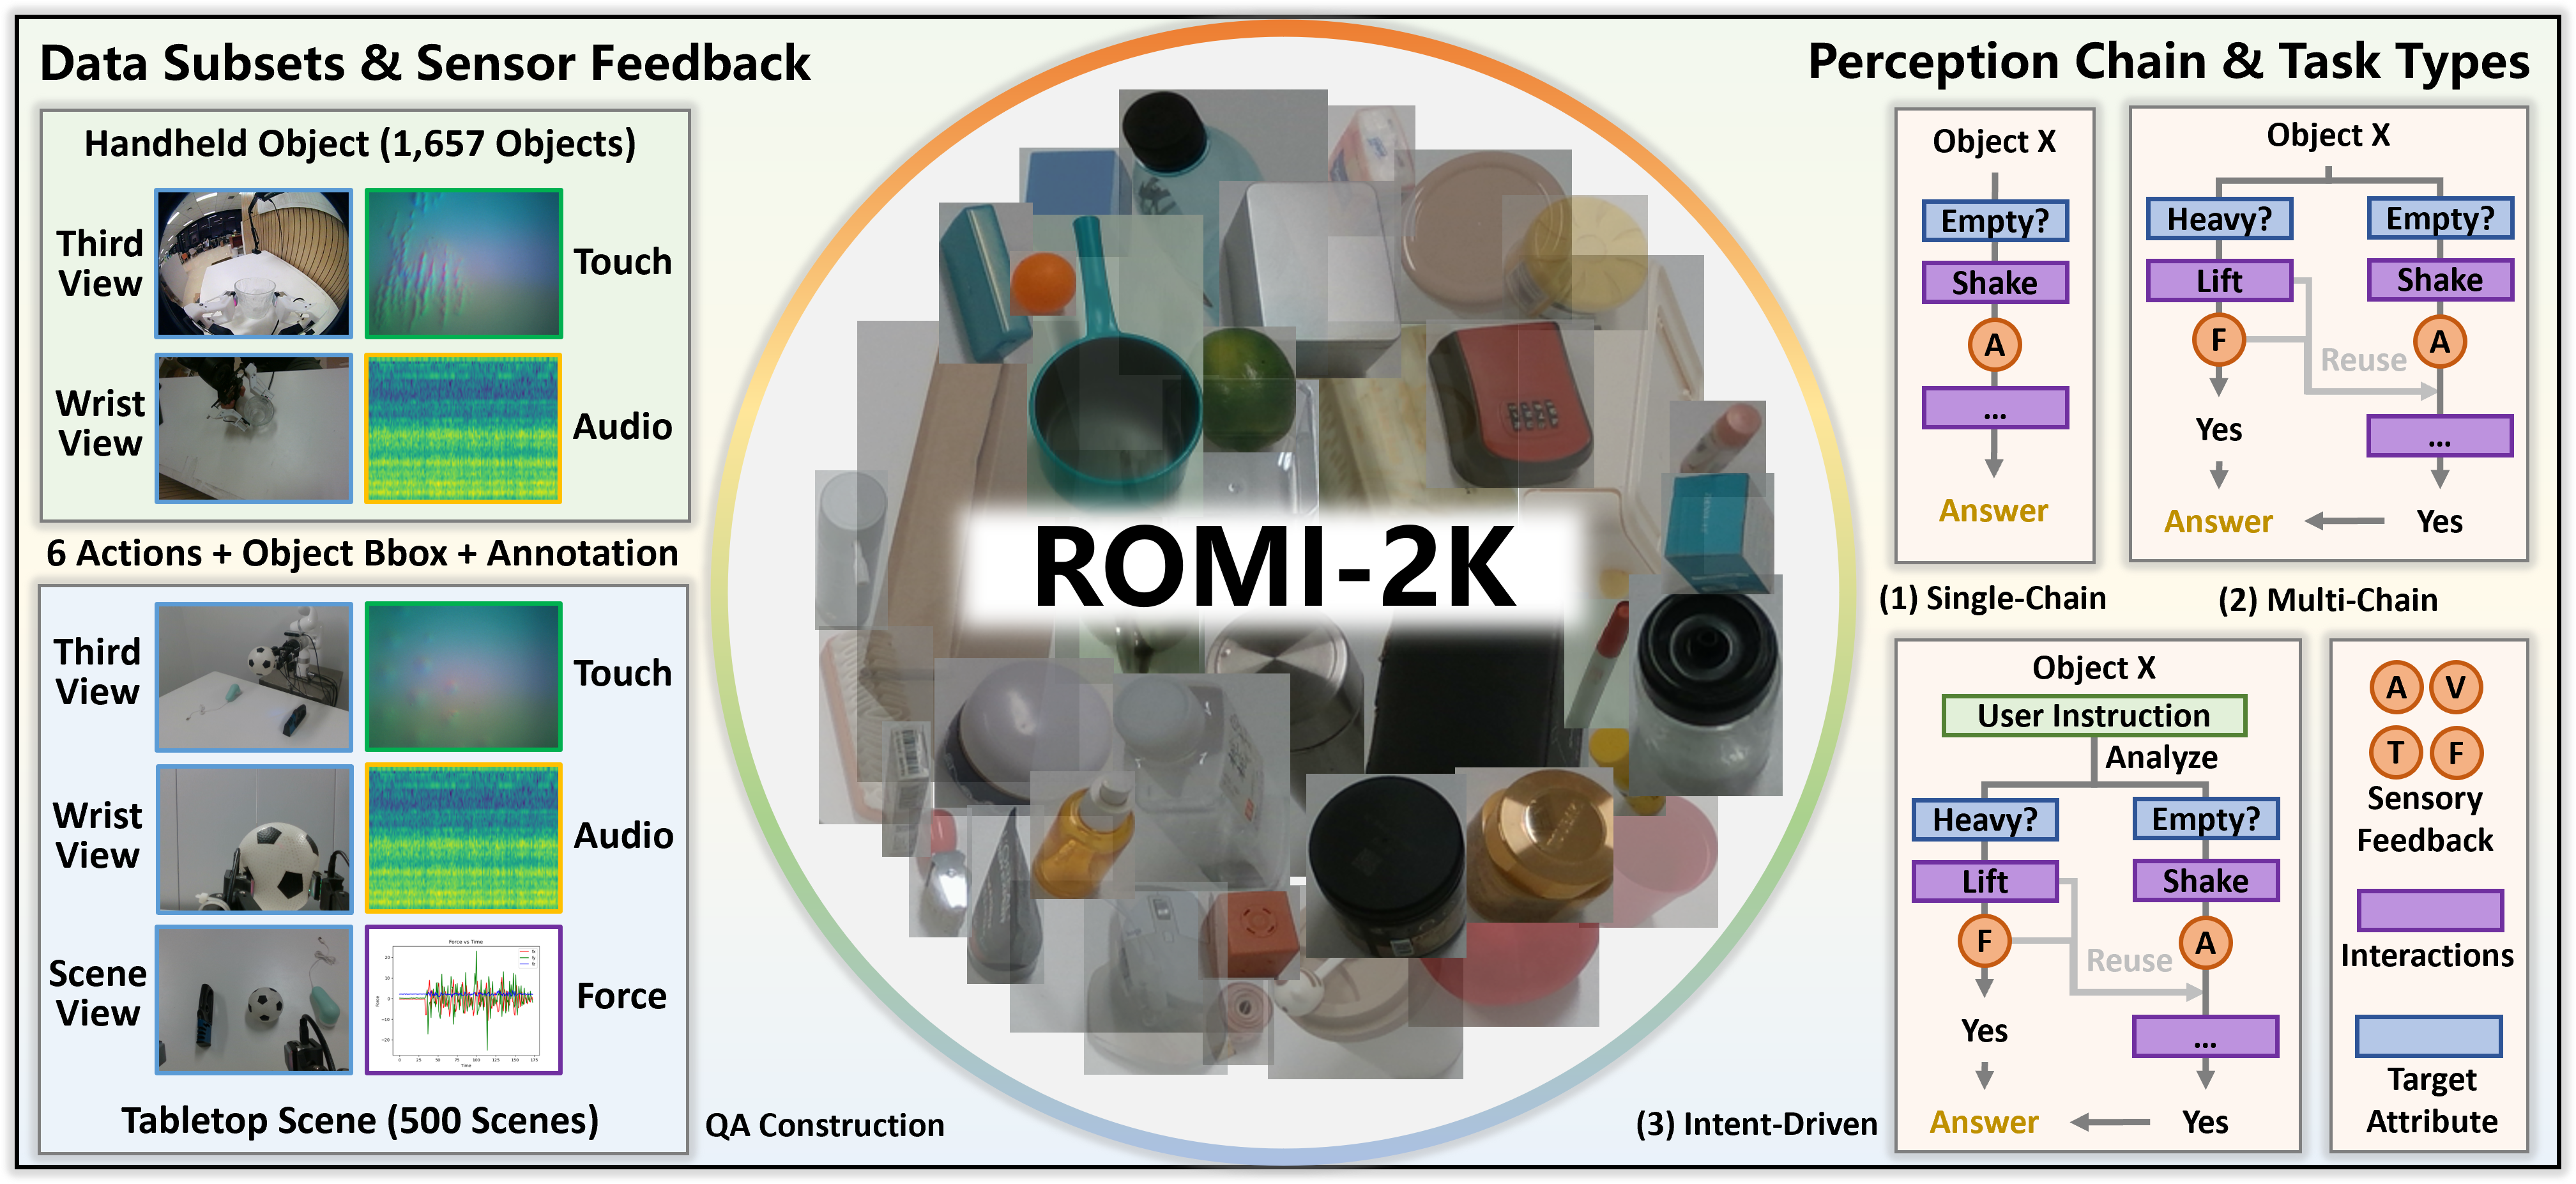
ROMI-2K is a real-world multi-sensory object interaction dataset covering nearly 2,000 objects and 6 atomic interactions (lift, press, collide, shake, rotate, squeeze) with synchronized visual, audio, tactile, and force feedback. It also includes ROMA Bench, 2,100 scene-level tasks for evaluating active perception.
Status: The ROMA-Bench QA tasks and labels are now available in
roma_bench_tasks.json. The remaining data (including the images, tactile, and other sensory files referenced by the tasks) is being prepared and will be uploaded to the directories below.
ROMA/
├── Handheld/          # Handheld object collection              (coming soon)
├── Tabletop-train/    # Tabletop scene collection, training set (coming soon)
└── ROMA-Bench/        # Scene-level evaluation tasks            (✅ updated 2026-10-20)

roma_bench_tasks.json  # ROMA-Bench QA tasks and labels          (✅ updated 2026-10-20)
| Directory | Description | Status |
|---|---|---|
Handheld |
1,657 object-content combinations, each interacted with at 3 grasp locations using 6 atomic interactions, with wrist and third-person views, audio, and tactile feedback. | Coming soon |
Tabletop-train |
400 tabletop scenes recorded with a robotic arm, with visual, audio, tactile, and force feedback, object bounding boxes, and annotations. | Coming soon |
ROMA-Bench |
2,100 scene-level active-perception tasks (single-chain, multi-chain, and intent-driven) built from the 100 tabletop scenes with unseen objects. QA tasks and labels are in roma_bench_tasks.json. |
✅ Updated (2026-10-20) |
Download the dataset into the resources/datasets directory of the GitHub repository:
git clone https://github.com/GeWu-Lab/ROMA.git
cd ROMA
# see the GitHub README for environment setup

hf download GeWu-Lab/ROMA --repo-type dataset --local-dir resources/datasets
The ROMA-7B checkpoint and the demo do not require this dataset. See the GitHub repository for the demo, and GeWu-Lab/ROMA-7B for the checkpoint.
@article{feng2026roma,
  title   = {ROMA: LLM System for Real-World Object-Centric Multi-Sensory Active Perception},
  author  = {Feng, Ruoxuan and Chen, Yutong and Song, Ruihua and Yang, Huan and
             Wang, Zhongyuan and Yao, Guocai and Hu, Di},
  journal = {arXiv preprint arXiv:2610.06955},
  url     = {https://arxiv.org/abs/2610.06955},
  year    = {2026}
}